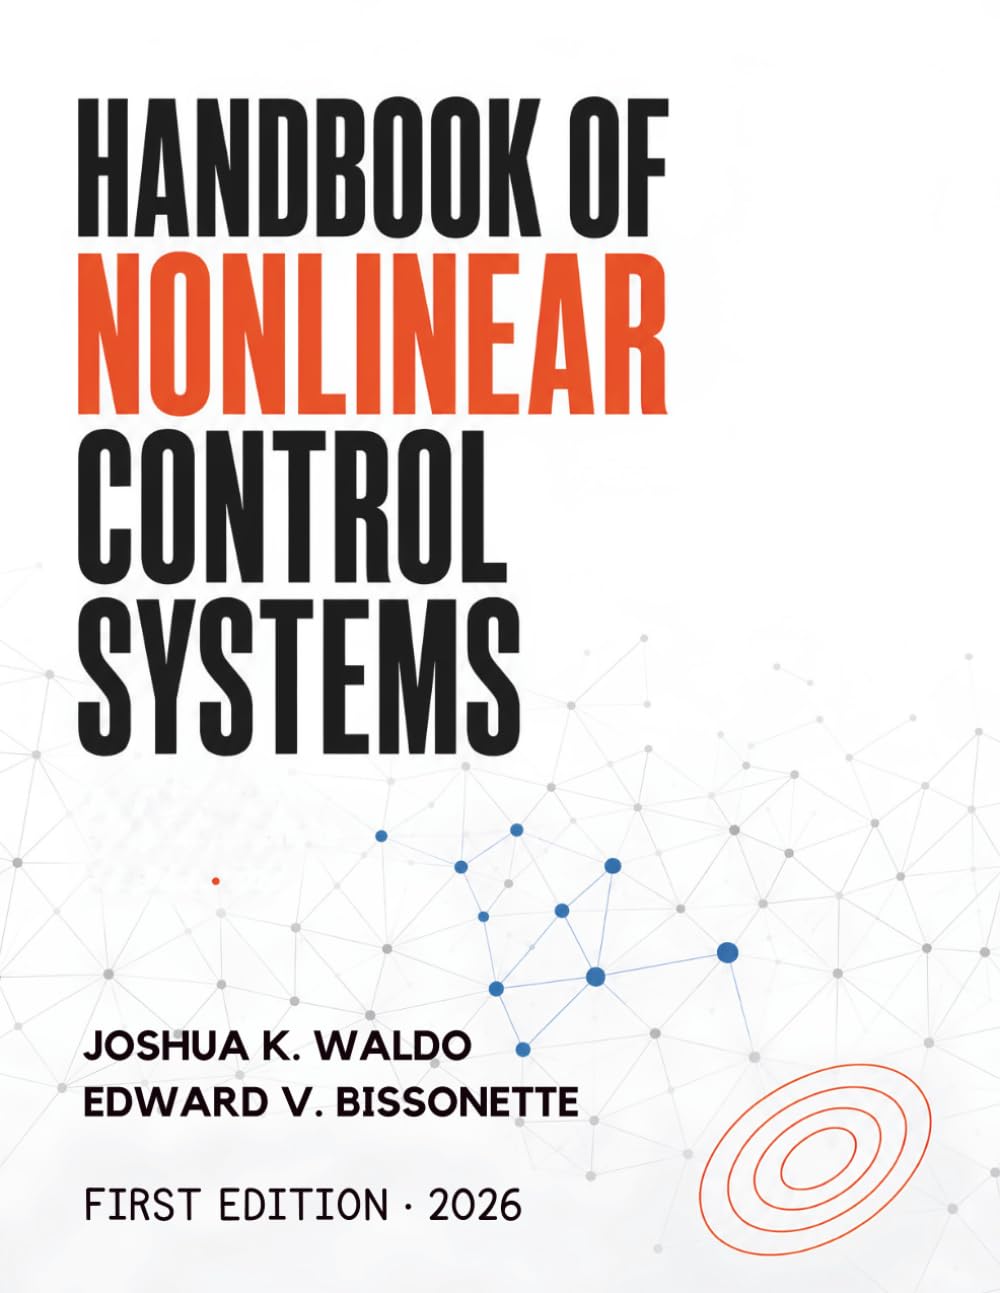
ler totalmente Handbook of Nonlinear Control Systems: Theory, Design, Simulation, and Engineering Applications
por Edward V Bissonette
Handbook of Nonlinear Control Systems: Theory, Design, Simulation, and Engineering Applications
Every physical control system is nonlinear underneath its linear approximation, and sooner or later - through actuator saturation, friction, backlash, or an operating range that outgrows a single set of gains - that approximation runs out. Engineers who have mastered linear control fundamentals often reach a point where the standard toolkit no longer explains what a system is doing. A controller tuned around one operating point starts to underperform, oscillate, or lose stability once the system moves into a regime where nonlinear effects dominate, and the available literature tends to split into two extremes: dense, mathematically abstract graduate texts that assume the reader already understands the material, and applied handbooks that present nonlinear techniques as recipes without the grounding needed to apply them safely. This handbook builds a complete, sequential path from the mathematical foundations of nonlinear behaviour through a full suite of modern nonlinear control design methods - developed with derivations, worked examples, computational implementation, and real engineering case studies at every stage - so the reader can move from recognising a nonlinear problem to designing, analysing, and deploying a working solution. Inside, you will learn how to: Coverage spans the mathematical and modelling foundations of nonlinear systems, geometric tools for feedback linearisation, sliding-mode and backstepping design, adaptive and robust control under uncertainty, energy-based and passivity-based design, safety-constrained and predictive control, hybrid and networked systems, data-driven and learning-assisted control, and the practical realities of digital implementation. These methods are illustrated through worked case studies, including a robotic manipulator, a magnetic levitation system, a path-following ground vehicle, and a power-electronic converter, along with two integrated, multi-technique capstone design projects. This handbook is written for senior undergraduates, beginning graduate students, and practising engineers in robotics, aerospace, automotive, biomedical devices, industrial process control, and power electronics who already understand linear control and are ready to work with systems that no longer behave linearly. Take the next step towards a genuinely comprehensive understanding of nonlinear control - add this handbook to your working library and start building the theory, computation, and design skills that practising control engineers actually use.
Procurando Handbook of Nonlinear Control Systems: Theory, Design, Simulation, and Engineering Applications? Aqui você encontra tudo sobre este livro de Edward V Bissonette em 29 de julho de 2026. Nesta página estão a descrição da obra, os detalhes da edição (532 páginas) e os formatos disponíveis para baixar: pdf, epub, txt, djvu. Se você gosta de Livros Internacionais, Ciências Tecnológicas, Matemática, Aplicada, Programação Linear, explore também outros títulos da mesma categoria no Encontrando os melhores livros. Veja ainda as outras obras de Edward V Bissonette em nosso catálogo.
Autores populares
Icon Group International (283) Publishing lmgdaw (250) Nikolay Krechet (145) Kennie B Journals (120) Charles Nehme (106) Riddler Books (105) webmarbook design (103) Mint and Cherry Notebooks (82) Jillo Trukudo (80) Ondrej Sarek (76) Iwona Makara (74) Just Visualize It (71) Moonpeak Library (69) Quick Witted Coconut (69) Mary Hirose (67) Talor Press (67) Various (67) Marina Buchholz B.Eng (58) Miller Sye (58) NAK Legal Publishing (58)Principais publicadores
Independently published Forgotten Books Routledge Taschen Dover Publications Wiley Oxford University Press CRC Press Kessinger Publishing Princeton University Press Cambridge University Press Springer Bloomsbury Academic O'Reilly Media Hal Leonard Publishing Corporation Tuttle Publishing Rizzoli International Publications Content provided by MemoryLane.com Editorial Tirant lo Blanch Thames & Hudson